UPDATE (October 2026): the original install command has been replaced. This post was written in August 2019 and told you to run a setup script from my personal Bitbucket repo:
curl -sSL https://bitbucket.org/dellarb/ardupilot-sitl/raw/master/sitl_install.sh | sudo bash
Do not run that, and please don’t run anything shaped like it. Three things were wrong with it: it piped a remote script straight into sudo bash, the script targeted Ubuntu 14.04 (end-of-life since 2019), and it pointed at a personal repo that is no longer maintained. ArduPilot moved to GitHub years ago, and the project maintains its own supported setup script. The instructions below now use that instead.
For those who use and develop using the ArduPilot autopilot software (as featured on DIY Drones and ArduPilot Discourse), a powerful simulation tool is available that can replicate all of the features of the autopilot without flying an actual aircraft. This is extremely useful for testing complex missions or parameter configurations without risking real hardware.
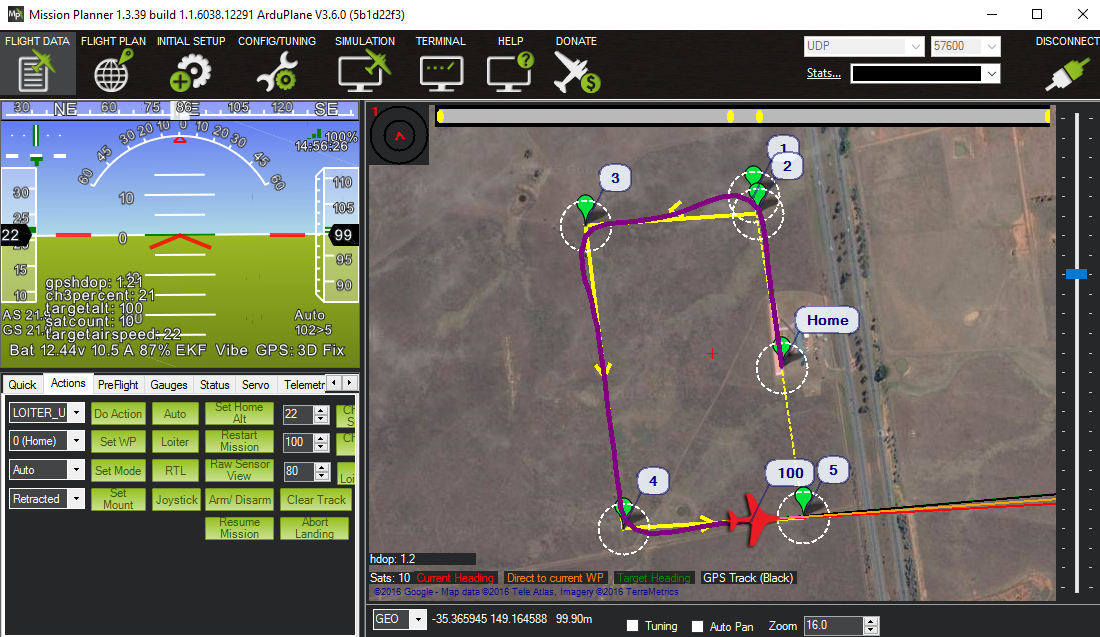
Setting it up used to be a bit tricky. The official instructions are at Setting up SITL on Linux, and the source lives at github.com/ArduPilot/ardupilot.